Soft Robotics
17 reportsThe main lines of inquiry around Soft Robotics include real-world operating limits; sensing and perception; and planning and control. Complementary views of planning and control come from safety and failure data and controlled tests, but the conclusion remains bounded because the strongest interpretation still recognizes that laboratory demonstrations may not generalize to cluttered or unpredictable environments.

Fluffy Robot MOFU Tested for Lifelike Movement in Animacy Study
A Japanese team built MOFU, a spherical robot that expands and contracts its body to test whether volumetric movement makes machines seem more alive. Nearly 500 participants rated its lifelikeness in controlled video experiments
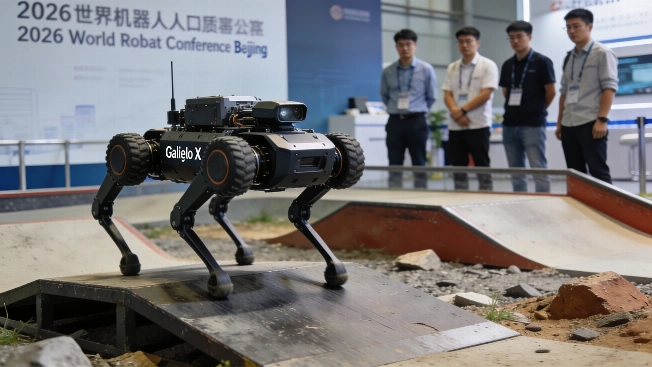
Galileo X Robot Platform Unifies Wheels, Legs, and Off-Road Mobility
Galileo Robotics has introduced Galileo X, a modular ground robot platform that merges wheeled, legged, and off-road mobility in a single system, aiming to simplify deployment across warehouses, rough terrain, and complex environments
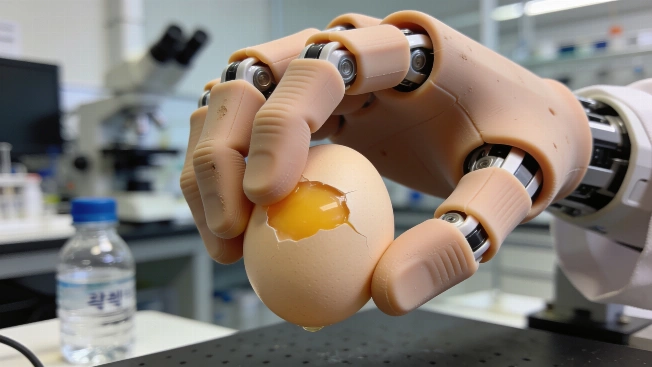
3D-Printed Soft Robotic Hand Shows Delicate Grip and Strength in Lab Tests
A research team at KAIST has built a 3D-printed soft robotic hand that can cradle fragile objects and lift heavy ones, using AI to optimize the material's stretchability and durability for advanced manipulation tasks

Drone Uses Tactile Sensing to Perch on Branches and Save Power
Researchers at TU Delft have built a drone that uses tactile sensors to locate and grip branches, allowing it to perch in cluttered environments and conserve battery by shutting down its motors once attached
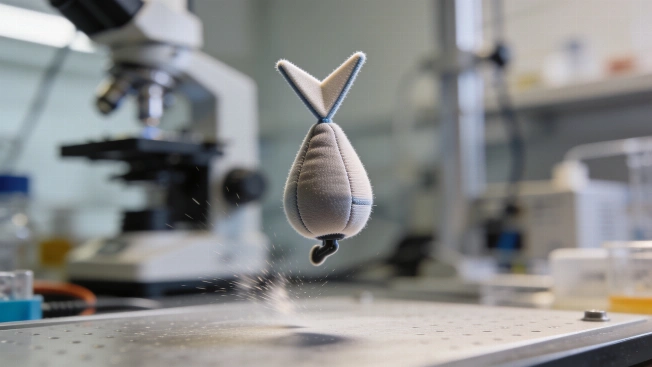
Soft Robots Demonstrate Continuous Jumping Using Infrared Light
Engineers at North Carolina State University have built soft robots that can repeatedly jump when illuminated by infrared light, using a self-resetting mechanical design that eliminates the need for motors or external resetting devices
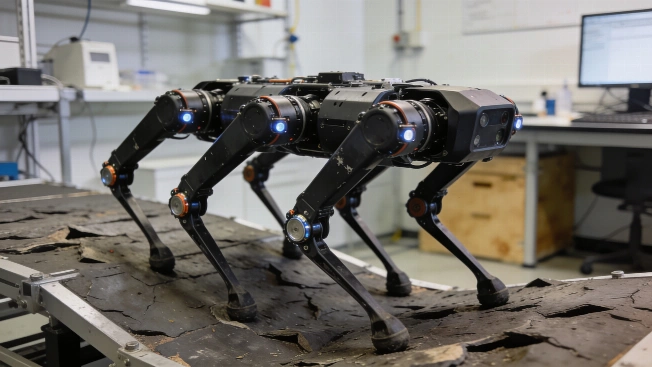
Six-Legged Robot Learns Adaptive Walking From Stick Insect Movements
A research team has developed a six-legged robot that uses AI to learn walking strategies from stick insect movement data, enabling it to adapt to uneven terrain and physical damage in laboratory tests
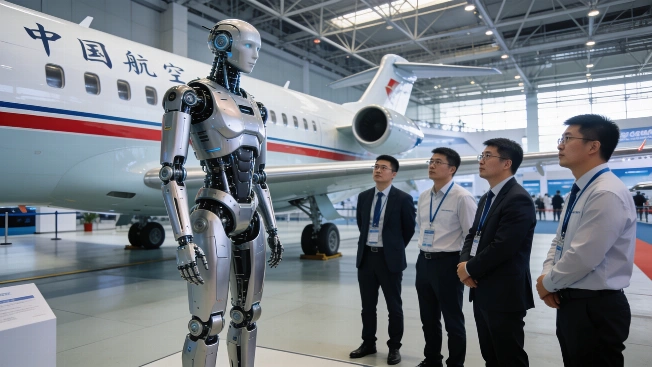
Chinese Robotics Firms Demonstrate Humanoids for Aviation and Security Tasks
At the 2026 World Robot Conference in Beijing, Chinese companies are presenting humanoid and quadruped robots for aviation, security, and industrial roles, with demonstrations highlighting both technical progress and ongoing challenges in real-world deployment
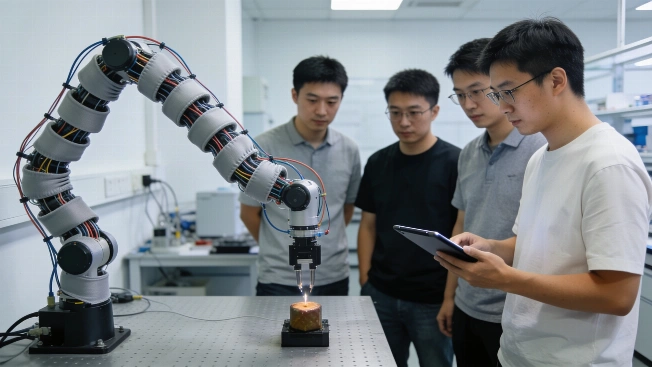
Feagine's Fi0 Model Tested for Cross-Body Robot Task Transfer
Feagine Robotics has introduced Fi0, a foundation model designed to transfer task knowledge across different soft robot arms, aiming to reduce retraining when hardware changes. Early tests used three tendon-driven manipulators with varying morphologies
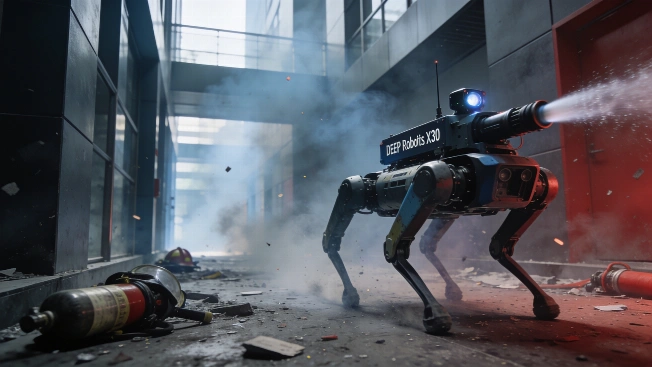
DEEP Robotics Deploys Quadruped Robots for Hazardous Fire Response
DEEP Robotics has begun deploying its X30 quadruped and Lynx M20 wheeled-legged robots to perform initial reconnaissance in hazardous firefighting and emergency environments, aiming to reduce human exposure during early assessment and support operations
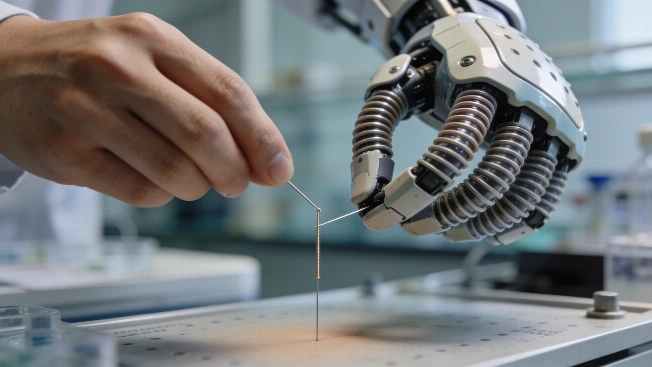
China Tests BioflexBot Hand for Precision Tasks With Simple Design
Researchers in China have built BioflexBot, a robotic hand that uses compressed air and a coiled spring to perform precise manipulations such as threading needles and opening bottle caps, aiming to reduce hardware complexity and cost
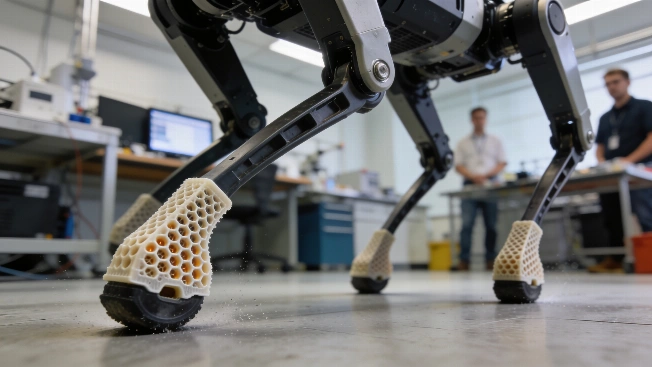
3D-Printed Porous Feet Cut Power Use in Quadruped Robot Tests
A research team at Seoul National University of Science and Technology has tested 3D-printed porous feet on a quadruped robot, reporting up to 6.2% lower battery consumption during walking tasks with a learning-based controller
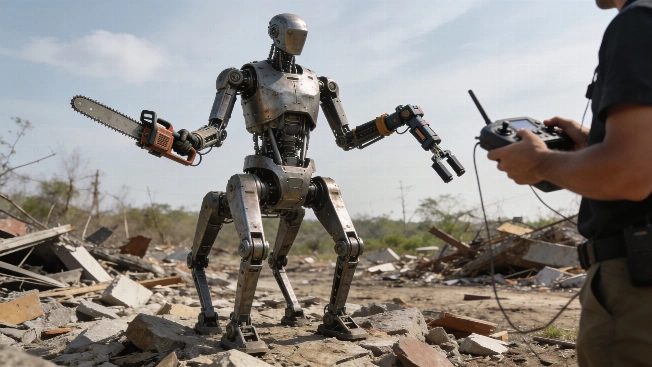
Centaur-Inspired Robot Threehalves Demonstrated for Hazardous Environments
A steel centaur-like robot called Threehalves has drawn attention for its four-legged design and modular tool system, aiming to perform dangerous tasks in unstable or hazardous settings where conventional robots struggle
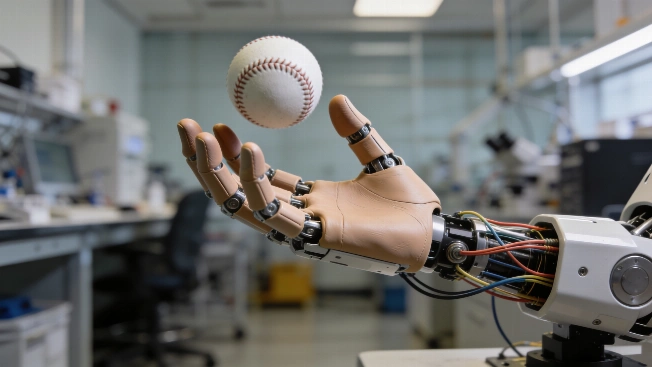
Foundation Robotics Tests Dexterous Hand Catching Baseball in Mid-Flight
Foundation Robotics has demonstrated a tendon-driven robotic hand that can catch a baseball in mid-air, highlighting advances in mechanical design, adaptive grasping, and sensor integration for industrial humanoid robots
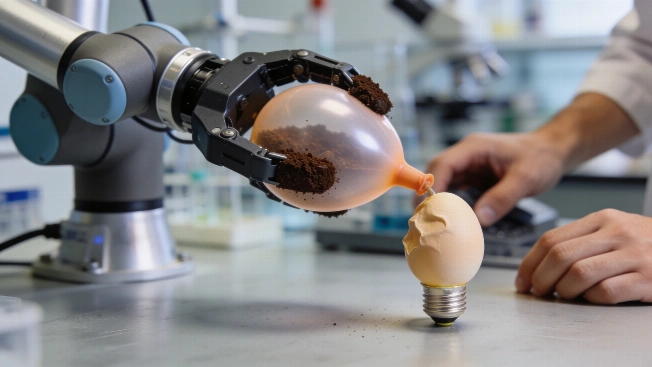
Coffee-Filled Soft Gripper Shows Low-Cost Robotic Handling Advance
A soft robotic gripper using a latex membrane and coffee grounds has demonstrated the ability to securely grasp fragile and irregular objects without cameras or complex sensors, offering a low-cost alternative for robotic manipulation tasks
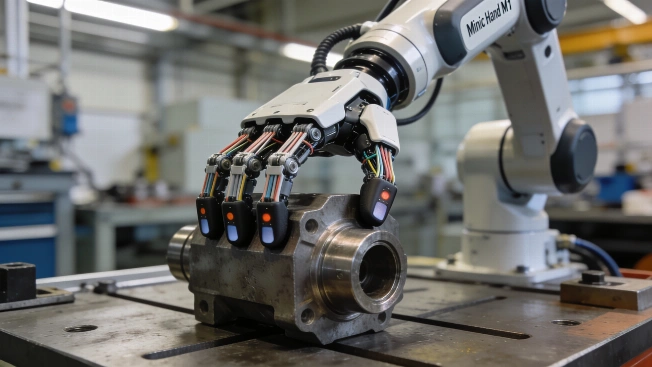
Swiss Startup Mimic Robotics Reveals Sensor-Rich Robotic Hand for Factories
Mimic Robotics has introduced the Mimic Hand M1, a tendon-driven robotic hand designed for industrial automation, featuring advanced tactile sensing and a human-like joint structure to improve manipulation of diverse objects in real-world settings
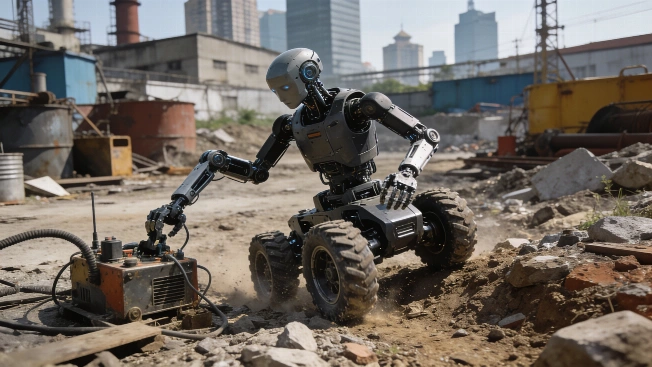
Hybrid wheel-leg robot from China targets industrial and rescue tasks
Run Robotics has demonstrated a wheel-leg hybrid robot at WAIC 2026, combining rapid wheeled movement with robotic arms for inspection, firefighting, and emergency response in complex environments. Most components are domestically sourced
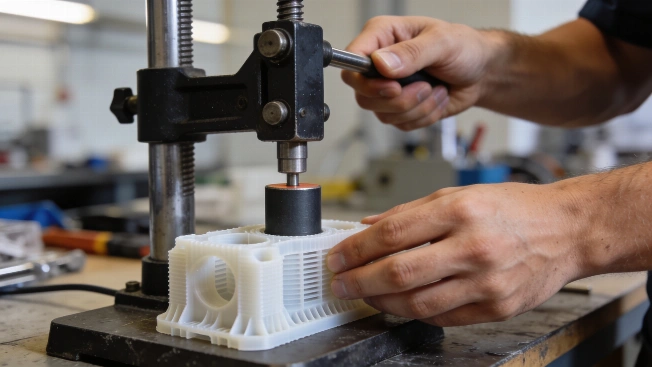
Evaluating Seven Methods for Embedding Magnets in 3D-Printed Parts
A recent demonstration compared seven techniques for installing magnets into 3D-printed components, assessing their mechanical reliability, ease of assembly, and long-term durability without relying on adhesives